Festo
HEPP-28-30-EC-B — HEPP Parallel Gripper - 15 mm stroke per jaw
HEPP Parallel Gripper - 15 mm stroke per jaw, electrical
Part number HEPP-28-30-EC-B · Order no. 8146667
Overview
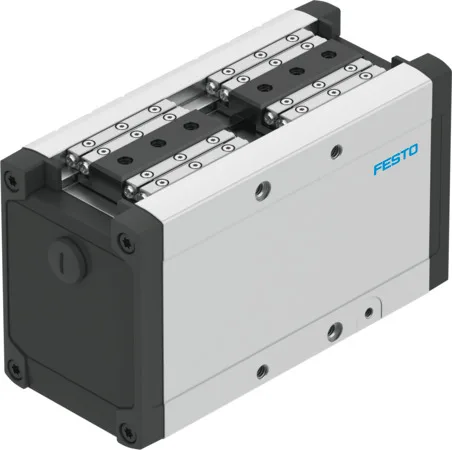
Parallel gripper HEPP-28-30-EC-B. Size [mm]: 28 mm; Bus protocol/activation: EtherCAT®; Brake: With brake; Stroke per gripper jaw [mm]: 15 mm
Technical data
| Size | 28 |
|---|---|
| Total stroke | 30 mm |
| Stroke per gripper jaws | 15 mm |
| Max. gripper jaw clearance Sy | ≤ 0.35 mm |
| Repetition accuracy in ± mm | 0.04 mm |
| Number of gripper jaws | 2 |
| Drive system | Electrical |
| Mounting position | Any |
| Controller operating mode | Interpolated mode via fieldbus |
| Gripper function | Parallel |
| Design | Toothed belt, Electric gripper, With brake, With ball screw |
| Guide | Roller bearing guide |
| Position detection | Motor encoder |
| Configuration support | ESI file |
| Variants | Metals with copper, zinc or nickel by mass as main constituent are excluded from use. Exceptions are nickel in steel, chemically nickel-plated surfaces, printed circuit boards, cables, electrical plug connectors and coils. |
| Rotor position sensor | Absolute encoder, single turn |
| Rotor position sensor, encoder measuring principle | magnetic |
| Ready status indication | LED |
| Positioning speed per gripper finger | ≤ 40 mm/s |
| Positioning acceleration per gripper finger | ≤ 1 m/s² |
| Gripping speed per gripper finger | 3 mm/s |
| Number of MAC addresses | 4 |
| Max. current consumption | 3000 mA |
| Max. current consumption, load | 2 A |
| Max. current consumption, logic | 1 A |
| Nominal operating voltage DC | 24 V |
| Nominal voltage for logic power supply DC | 24 V |
| Nominal voltage load voltage DC | 24 V |
| Nominal motor current | 0.9 A |
| Permissible range for load power supply | ±10% |
| Permissible range for logic voltage | ±10% |
| KC mark | KC-EMV |
| CE mark (see declaration of conformity) | To EU EMC Directive, In accordance with EU RoHS Directive |
| UKCA marking (see declaration of conformity) | To UK RoHS instructions |
| Shock resistance | Shock test with severity level 2 to FN 942017-5 and EN 60068-2-27 |
| Corrosion resistance class CRC | 0 - No corrosion stress |
| LABS (PWIS) conformity | VDMA24364 zone III |
| Suitability for the production of Li-ion batteries | Suitable for battery production with reduced Cu/Zn/Ni values (F1a) |
| Cleanroom suitability, measured according to ISO 14644-14 | Class 6 according to ISO 14644-1 |
| Vibration resistance | Transport application test with severity level 2 to FN 942017-4 and EN 60068-2-6 |
| Relative air humidity | Non-condensing |
| Sound pressure level | 60 dB(A) |
| Degree of protection | IP40 |
| Ambient temperature | 0 °C ... 50 °C |
| Total gripping force | 320 N |
| Gripping force per gripper jaw | 160 N |
| Mass moment of inertia | 30 kgcm² |
| Max. force on gripper jaw Fz static | 680 N |
| Max. torque at gripper Mx static | 6.5 Nm |
| Max. torque at gripper My static | 14.5 Nm |
| Max. torque at gripper Mz static | 6.5 Nm |
| Rated load | 1 kg |
| Nominal torque | 0.115 Nm |
| Lubrication interval for guide components | 1 Mio SP |
| Product weight | 1400 g |
| Communication profile | CiA402, EoE (Ethernet over EtherCAT), FoE (File over EtherCAT) |
| Field bus, connection type | Socket |
| Field bus, connection system | M12x1, D-coded to EN 61076-2-101 |
| Field bus, connection pattern | 4 |
| Field bus, protocol | EtherCAT® |
| Electrical connection | 2x M12 |
| Fieldbus link | EtherCAT® |
| Type of mounting | Via female thread and centring sleeve |
| Note on materials | RoHS compliant |
| Material housing | Anodised aluminium |
| Material gripper jaws | Steel |
Similar products
DHPC Parallel gripper DHPC 10 24 models
DHPC Parallel gripper DHPC 16 24 models
DHPC Parallel gripper DHPC 20 24 models
DHPC Parallel gripper DHPC 25 24 models
DHPC Parallel gripper DHPC 32 12 models
DHPC Parallel gripper DHPC 40 12 models