Festo
HPPF-8-8-A — HPPF Parallel Gripper - 4 mm stroke per jaw
HPPF Parallel Gripper - 4 mm stroke per jaw, pneumatic
Part number HPPF-8-8-A · Order no. 8133724
Overview
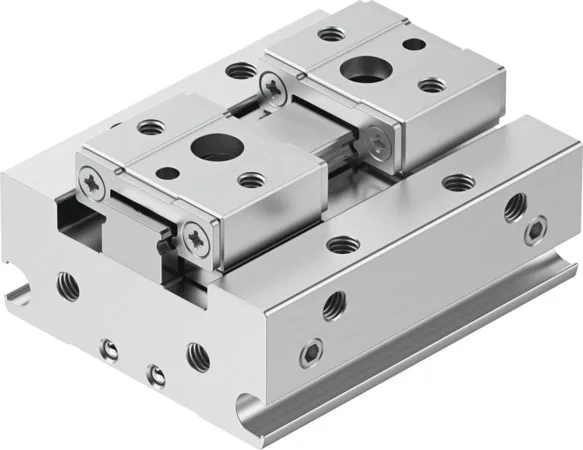
Parallel gripper HPPF-8-8-A. Design: Flat mounting method for gripper fingers, Rack and pinion, Force pilot operated motion sequence; Stroke per gripper jaws: 4 mm; Position detection: Via proximity switch; Pneumatic connection: M3
Technical data
| Size | 8 |
|---|---|
| Total stroke | 8 mm |
| Stroke per gripper jaws | 4 mm |
| Max. angular gripper jaw backlash ax, ay | 0° |
| Max. gripper jaw backlash Sz | 0 mm |
| Repetition accuracy, gripper | ≤ 0.03 mm |
| Number of gripper jaws | 2 |
| Drive system | Pneumatic |
| Mounting position | Any |
| Mode of operation | Double-acting |
| Cushioning | Elastic cushioning rings/plates at both ends |
| Gripper function | Parallel |
| Gripper force back-up | None |
| Design | Flat mounting method for gripper fingers, Rack and pinion, Force pilot operated motion sequence |
| Guide | Ball guide |
| Position detection | Via proximity switch |
| Variants | Metals with copper, zinc or nickel by mass as main constituent are excluded from use. Exceptions are nickel in steel, chemically nickel-plated surfaces, printed circuit boards, cables, electrical plug connectors and coils. |
| Operating pressure | 0.15 MPa ... 0.7 MPa / 1.5 bar ... 7 bar / 21.75 psi ... 101.5 psi |
| Max. operating frequency of gripper | 2 Hz |
| Min. opening time at 0.6 MPa (6 bar, 87 psi) | 15 ms |
| Min. closing time at 0.6 MPa (6 bar, 87 psi) | 12 ms |
| Max. mass per external gripper finger | 20 g |
| Operating medium | Compressed air to ISO 8573-1:2010 [7:4:4] |
| Note on operating and pilot medium | Lubricated operation possible (in which case lubricated operation will always be required) |
| Corrosion resistance class CRC | 0 - No corrosion stress |
| LABS (PWIS) conformity | VDMA24364 zone III |
| Suitability for the production of Li-ion batteries | Suitable for battery production with reduced Cu/Zn/Ni values (F1a) |
| Ambient temperature | -10 °C ... 60 °C |
| Total gripping force, opening, 0.6MPa (6bar, 87 psi) | 54.44 N |
| Total gripping force, closing, 0.6MPa (6bar, 87 psi) | 54.44 N |
| Gripper force per gripper jaw, opening, 0.6 MPa (6 bar, 87 psi) | 27.22 N |
| Gripper force per gripper jaw, closing, 0.6 MPa (6 bar, 87 psi) | 27.22 N |
| Max. force on gripper jaw Fz static | 60 N |
| Max. moment Mx | 0.9 Nm |
| Max. moment My | 0.4 Nm |
| Max. moment Mz | 0.4 Nm |
| Product weight | 68 g |
| Type of mounting | Direct mounting via through-hole, Direct mounting via thread |
| Pneumatic connection | M3 |
| Note on materials | RoHS compliant |
| Material cover cap | Wrought aluminium alloy, anodised |
| Material cover | Anodised wrought aluminium alloy |
| Material end plate | High-alloy stainless steel |
| Material housing | Anodised wrought aluminium alloy |
| Material gripper jaws | High-alloy steel |
| Material piston seal | TPE-U(PU) |
| Material o-ring | NBR |
| Material screws | Coated steel |
| Gear rack material | High-alloy stainless steel |
Often bought with
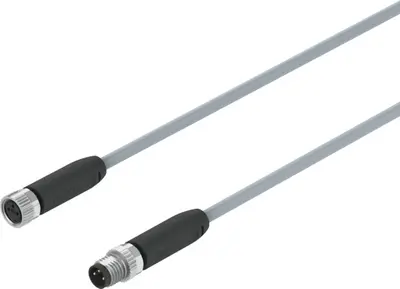
NEBA Connecting Cable - 1 m, M8x1 to M8x1 NEBA-M8G3-U-1-N-M8G3
NEBA Connecting Cable - 2.5 m, M8x1 to M8x1 NEBA-M8G3-U-2.5-N-M8G3
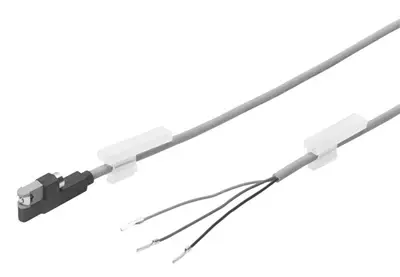
SMT Proximity Sensor - Magneto-resistive, NPN, For C-slot SMT-10G-NS-24V-E-2,5Q-OE
SMT Proximity Sensor - Magneto-resistive, NPN, For C-slot SMT-10M-NS-24V-E-2,5-L-OE
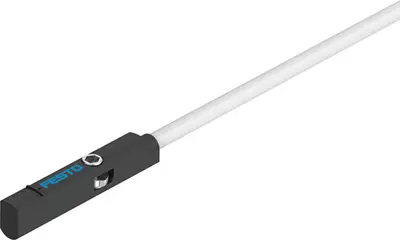
SMT Proximity Sensor - Magneto-resistive, NPN, For C-slot SMT-10M-NS-24V-E-0,3-L-M8D
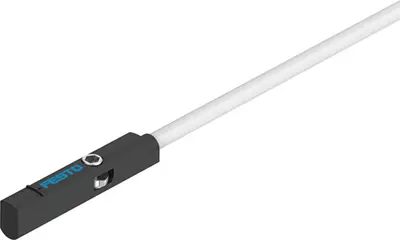
SMT Proximity Sensor - Magneto-resistive, NPN, For C-slot SMT-10G-NS-24V-E-0,3Q-M8D
SMT Proximity Sensor - Magneto-resistive, PNP, For C-slot SMT-10M-PS-24V-E-2,5-L-OE
SMT Proximity Sensor - Magneto-resistive, PNP, For C-slot SMT-10G-PS-24V-E-2,5Q-OE
Similar products
DHPC Parallel gripper DHPC 10 24 models
DHPC Parallel gripper DHPC 16 24 models
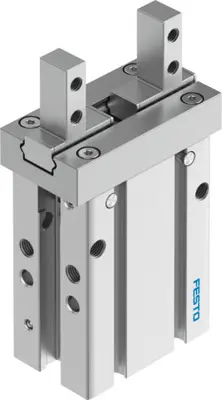
DHPC Parallel gripper DHPC 20 24 models
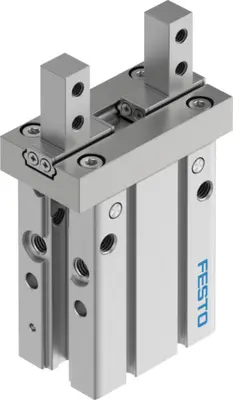
DHPC Parallel gripper DHPC 25 24 models
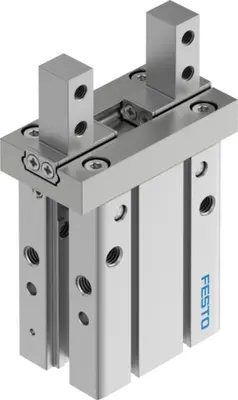
DHPC Parallel gripper DHPC 32 12 models
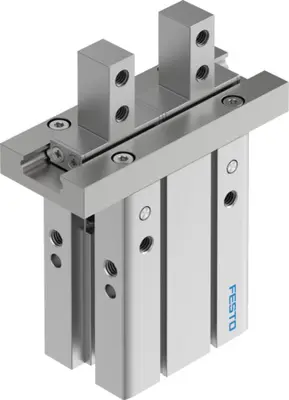
DHPC Parallel gripper DHPC 40 12 models