Festo
EHMD Rotary Gripper Module - 5 mm stroke per jaw
Part number EHMD-40-RE-GE
Overview
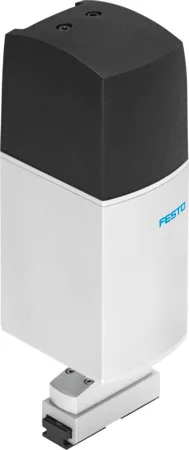
Rotary gripper module EHMD-40-RE-GE. Size [mm]: 40 mm; Rotary module drive system: Electric; Gripper drive system: Electric; Drive system: None
Technical data
| Size | 40 |
|---|---|
| Rotation angle | Infinite |
| Stroke per gripper jaws | 5 mm |
| Controllable stroke range per gripper jaw | 0 – 5 mm |
| Reversing backlash theoretical | 300 mm |
| Stepper angle for complete step | 1.8° |
| Step angle full step, rotation | 1.8° |
| Stepping angle tolerance | ±5% |
| Step angle tolerance, rotation | ±5% |
| Number of gripper jaws | 2 |
| Mounting position | optional |
| Design | Electric rotary drive, Electric gripper |
| Mode of operation | Electric parallel gripper |
| Operating mode, rotation | Hybrid stepper motor |
| Gear unit ratio | 1:1 |
| Position detection | Rotation: motor encoder, Gripping: motor encoder |
| Gripper function | Parallel |
| Type of motor | Stepper motor |
| Referencing | Rotation: encoder index, Gripping: fixed stop block |
| Rotor position sensor | Incremental encoder |
| Rotor position encoder interface | RS422 TTL AB channels + zero index |
| Rotor position sensor, encoder measuring principle | Optical |
| Max. drive output speed | 240 |
| Max. speed | 0.025 |
| Max. homing speed | 0.002 |
| Max. gripping speed per gripper jaw | 25 |
| Duty cycle | 100% |
| Insulation protection class | B |
| Max. current consumption | 60 mA |
| Max. current consumption, rotation | 60 mA |
| Nominal operating voltage DC | 24 V |
| Nominal operating voltage DC, rotation | 5 V |
| Note on motor nominal current | 0.5 A for gripper drive |
| Nominal voltage DC | 24 V |
| Phase winding inductance | 4 |
| Winding inductance phase, rotation | 11 |
| Phase winding resistance | 5.6 Ω |
| Winding resistance phase, rotation | 5.8 Ω |
| Pulses per revolution | 500 |
| Pulses per revolution, rotation | 500 |
| Nominal current per phase | 0.5 A |
| Nominal current per phase, rotation | 0.9 A |
| Approval | RCM trademark |
| KC mark | KC-EMV |
| CE mark (see declaration of conformity) | To EU EMC Directive, In accordance with EU RoHS Directive |
| UKCA marking (see declaration of conformity) | To UK instructions for EMC |
| Vibration resistance | Transport application test with severity level 1 to FN 942017-4 and EN 60068-2-6 |
| LABS (PWIS) conformity | VDMA24364 zone III |
| Storage temperature | -20 – 70°C |
| Relative air humidity | 0 - 85%, Non-condensing |
| Degree of protection | IP20 |
| Ambient temperature | 0 – 40°C |
| Gripping force per gripper jaw | 7 – 35 N |
| Residual gripping force in the event of a power failure | 10 N |
| Gripping force at nominal current | 35 N |
| Motor holding torque | 0.043 Nm |
| Holding torque motor, rotation | 0.3 Nm |
| Mass moment of inertia | 0.009 |
| Mass moment of inertia, rotation | 0.125 |
| Max. output torque | 0.3 Nm |
| Max. force on gripper jaw Fz static | 30 N |
| Max. torque at gripper Mx static | 0.7 Nm |
| Max. torque at gripper My static | 1.5 Nm |
| Max. torque at gripper Mz static | 0.7 Nm |
| Max. nominal load | 0.25 g |
| Feed constant | 1.48 |
| Product weight | 681 g |
| Electrical connection 1, function | 2x encoder, 2x motor |
| Electrical connection 1, connection type | Plugs |
| Electrical connection 1, connector system | Connection pattern F1 |
| Electrical connection 1, number of connections/cores | 31 |
| Electrical connection 1, connection pattern | 995929 |
| Type of mounting | Via dovetail slot |
| Note on materials | RoHS-compliant |
| Material cover | PA-reinforced |
| Material housing | Anodised wrought aluminium alloy |
Often bought with
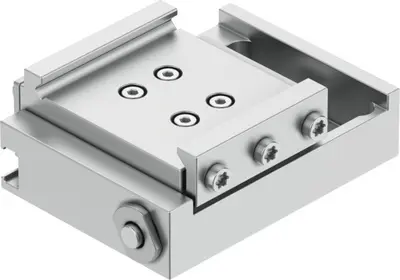
EHAM-E20-40-Z Mounting EHAM-E20-40-Z
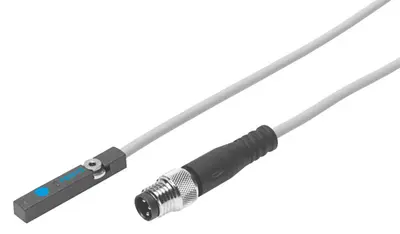
SIES Proximity Sensor - NO, 0.3 m SIES-8M-NO-24V-K-0,3-M8D
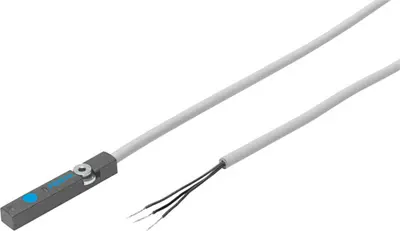
SIES Proximity Sensor - NO, 7.5 m SIES-8M-NO-24V-K-7,5-OE
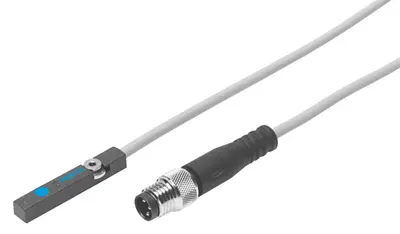
SIES Proximity Sensor - PNP, 1.5 mm, 0.3 m SIES-8M-PO-24V-K-0,3-M8D
SIES Proximity Sensor - PNP, 1.5 mm, 7.5 m SIES-8M-PO-24V-K-7,5-OE